 Inside AI
FEATURED DEEP DIVE
Inside the
AI HAT+
A camera can spot a bottle in dozens of frames. How do you get it to count that bottle just once?
 ++++
RASPBERRY PI AI HAT+PCIe / HAILO NPU
A camera can spot a bottle in dozens of frames. How do you get it to count that bottle just once?
++++A field guide to how they work, what you can try today, and what else they might do.
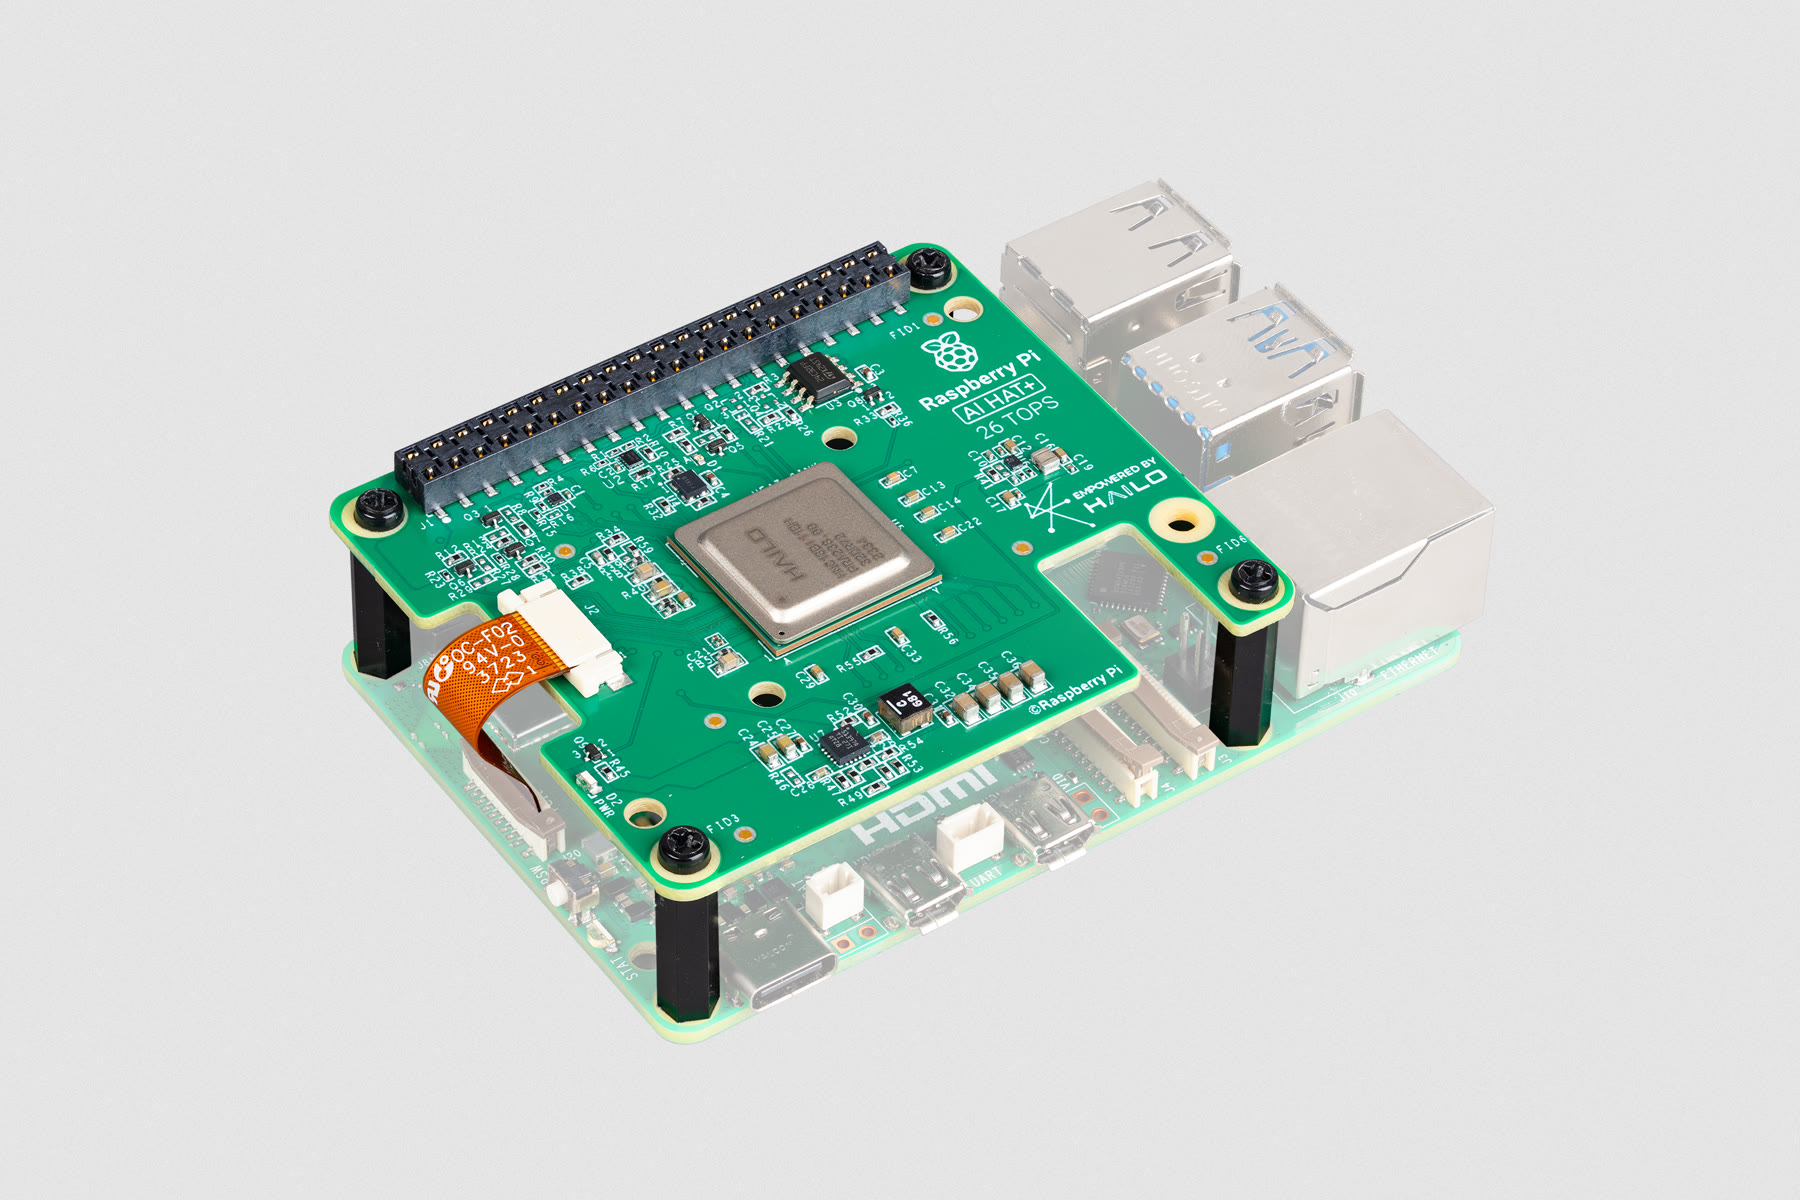
⌖A camera, a Linux host and a dedicated inference chip. Follow a frame through all three.
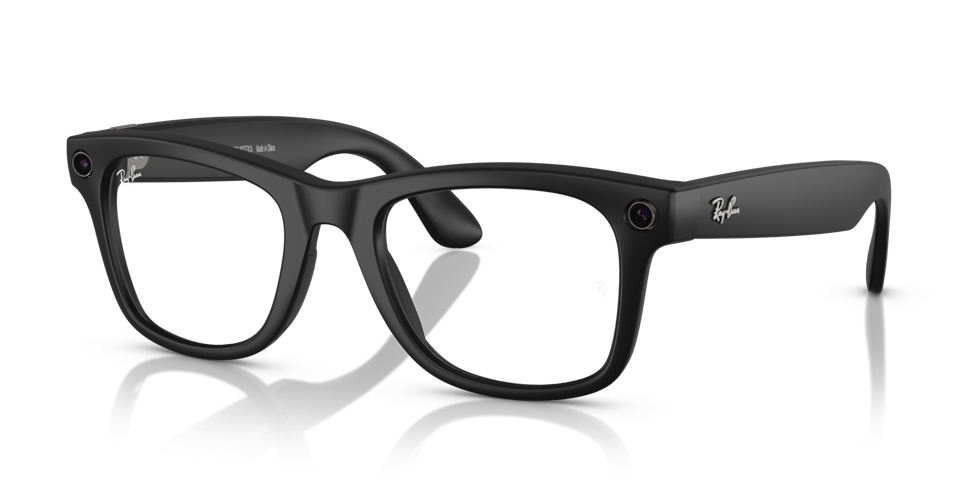 ⌖
Follow a Gen 1 camera frame from the glasses into a permitted Android session, then decide what the phone should keep.
 ⌖
Follow one meeting recording from the original NotePin’s microphones to an action item you can check against the speaker’s own words.
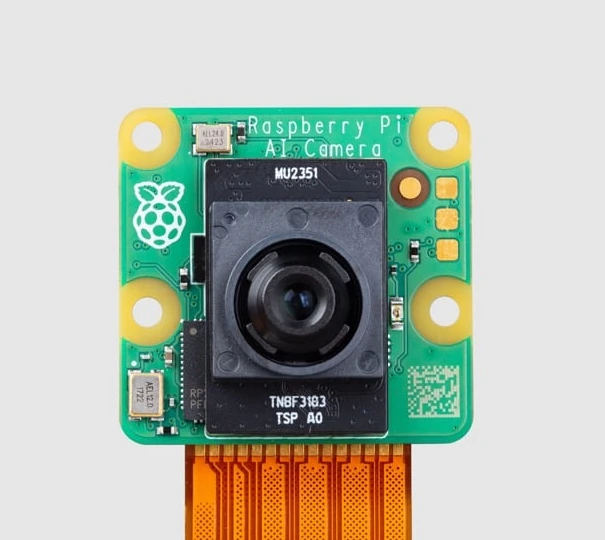 ⌖
One camera ribbon carries an image and a neural network’s answer about that image. The Pi decides what to do with each.
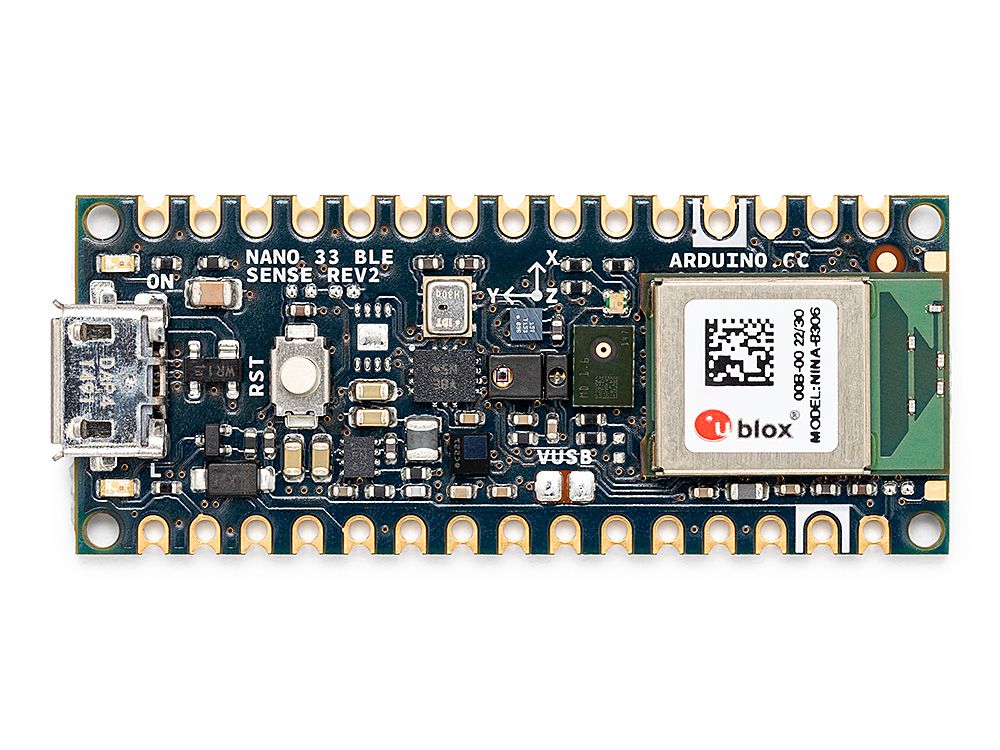 ⌖
Train a board to recognize a hand wave, then see what happens when someone else wears it.
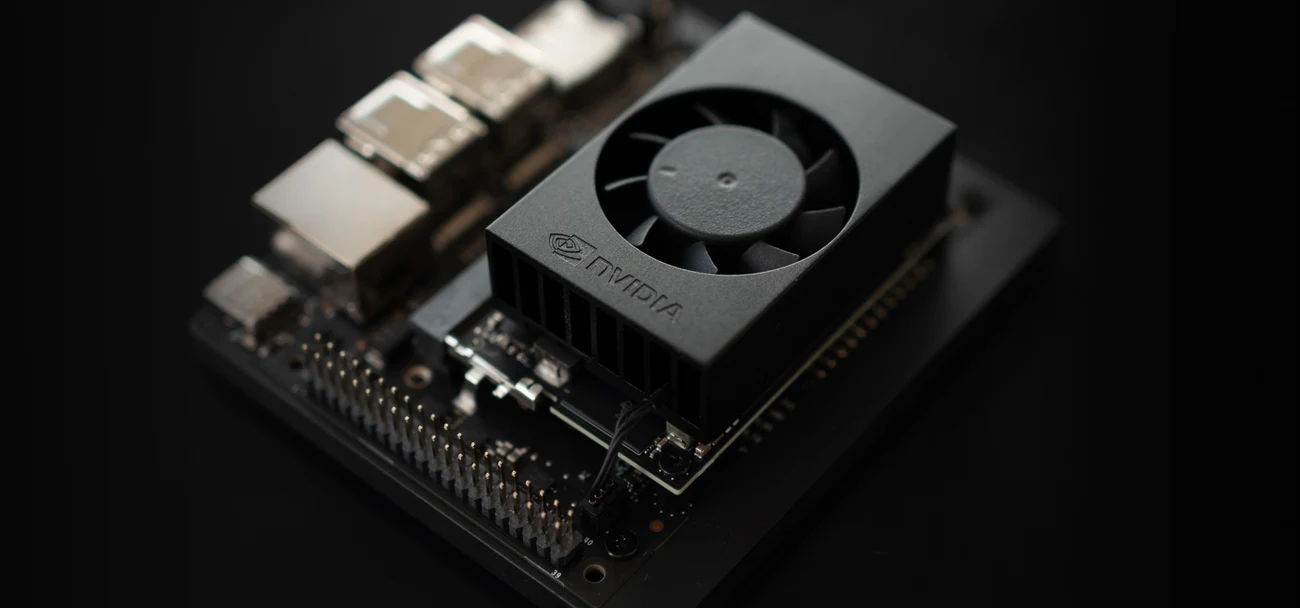 ⌖
Turn a repair note into a checked work order on a computer small enough to leave on the bench. Follow a prompt through its shared 8 GB of memory.
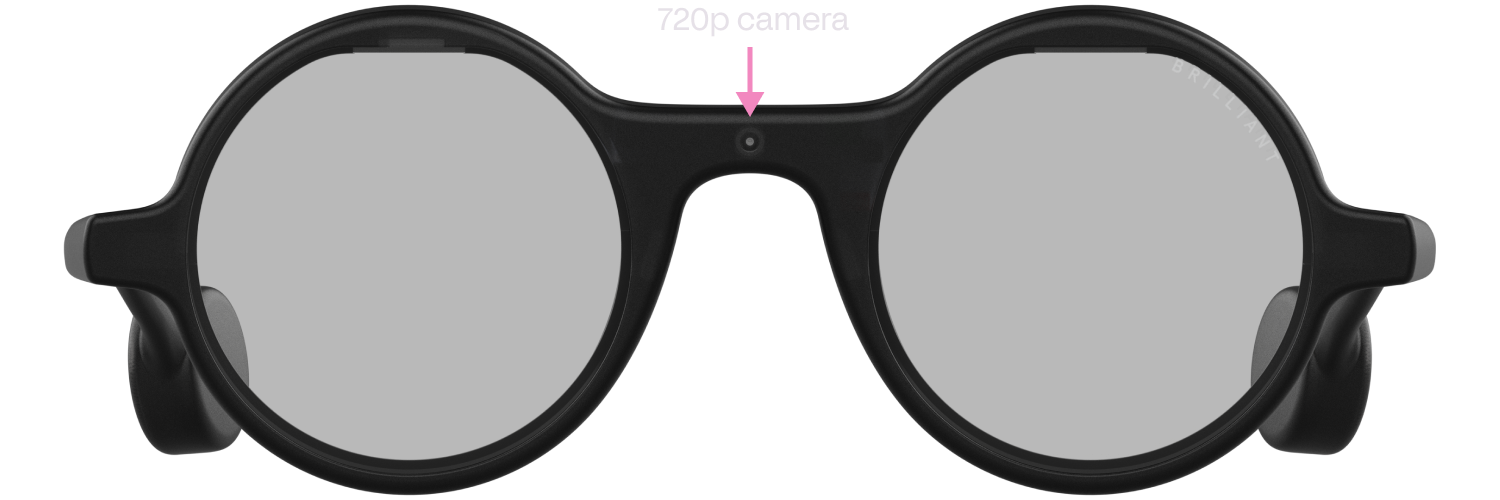 ⌖
A camera, microphone and tiny display you can program over Bluetooth. Original Frame remains documented; new-unit availability is unverified.
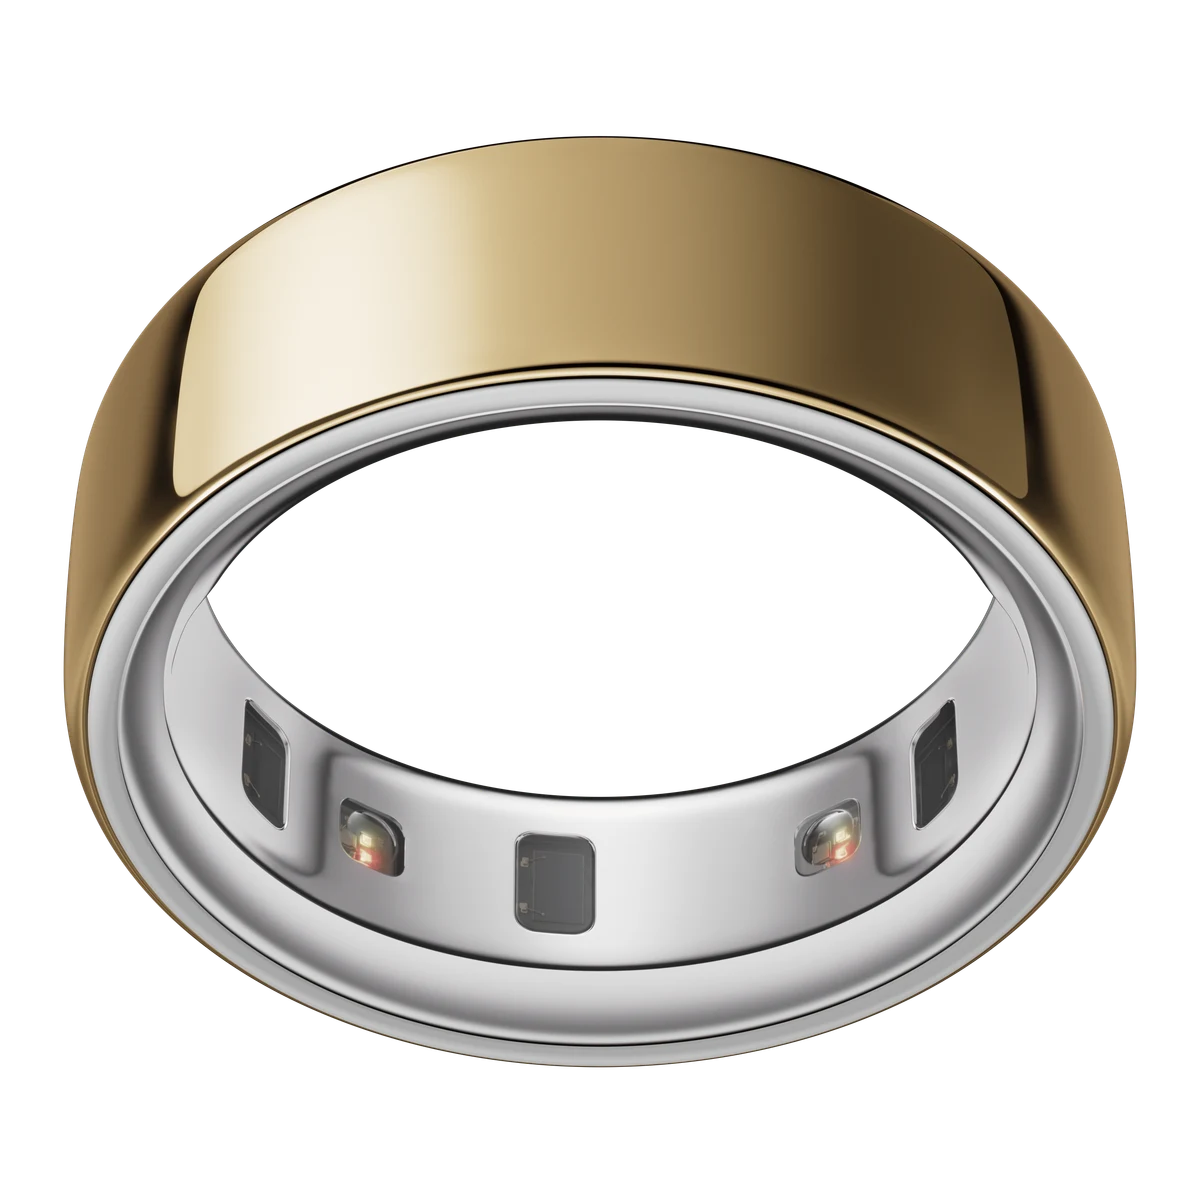 ⌖
A small ring turns optical and motion signals into daily records. Build a reflection journal that shows where its data ends and interpretation begins.
 ⌖
An open-source voice pendant with account APIs and published hardware files. Trace a spoken correction into a proposed task that stays linked to its transcript.
 ⌖
A small voice satellite with an unusually clear boundary: the puck listens and speaks, while your chosen Home Assistant pipeline decides what the words mean.
 ⌖
A detection box tells you what is in view. Two more cameras help estimate where it is. Build a distance-aware desk zone and inspect when that estimate fails.
 ⌖
Teach a thumb-sized camera to recognize a few bench states, then send a small event instead of a video stream. The hard part is making that decision survive new lighting.
 ⌖
Give a vision model a physical response: a glance, a nod or a curious tilt. This desktop robot lets you build the interaction loop and test whether its gestures actually help.
 ⌖
Turn a camera detection into a useful local event without adding a separate Pi host. The interesting part is the rule between “I see a bottle” and “the bottle has been removed.”